


Easy3DMatch
3D对准与检测库
- 将扫描的 3D 对象与另一份扫描数据或参考网格进行对齐
- 计算 3D 扫描数据与黄金样本或参考网格之间的局部距离
- 检测异常情况,例如特征位置偏移、几何畸变、间隙、凸起等
- 兼容所有可生成点云、深度图或高度图的 3D 传感器
描述
通过将3D数据与参考模型进行比较来检测异常
在将3D数据与参考模型对齐后,Easy3DMatch可检测局部偏差,例如孔洞、凸起、划痕、间隙等……系统会返回检测到的异常列表,并附带各自的位置、距离和面积信息。通过交互式eVision 3D查看器,可以生成并显示包含距离和彩色数据的新点云。
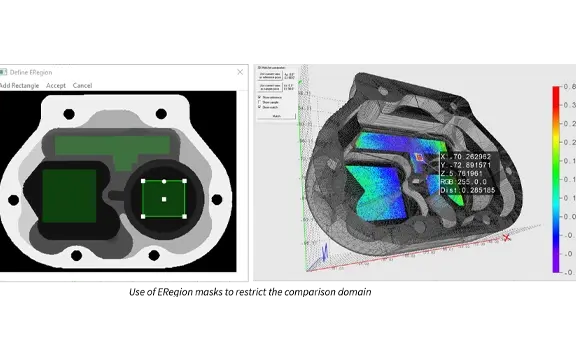
支持感兴趣的 2D 和 3D 子域
可以利用(在ZMap上的)任意2D区域和(在点云上的)3D体积来定义感兴趣的子域。在这种情况下,对齐过程中会使用整个对象,但在比较和异常检测时仅考虑其中的一部分。
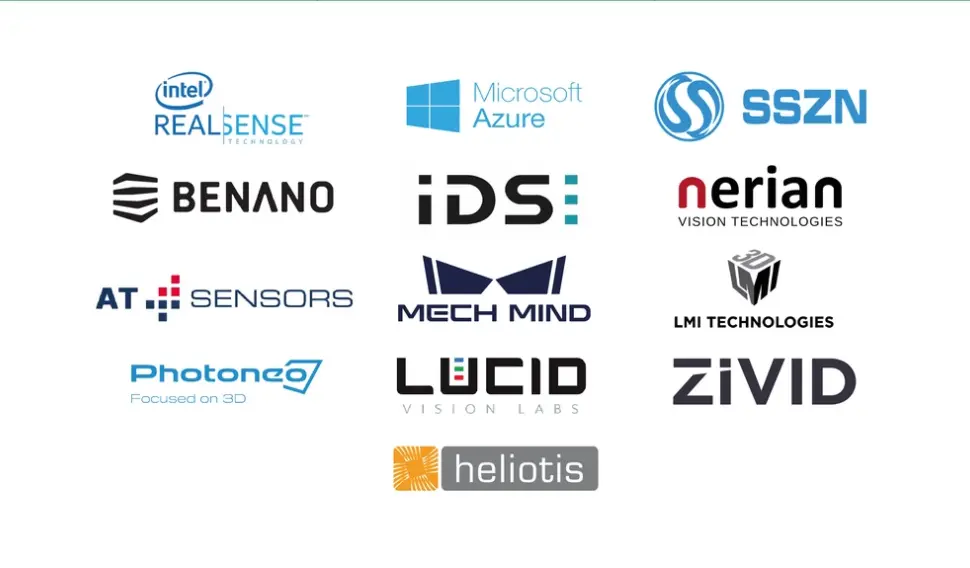
与3D传感器的兼容性
Easy3D 库能够导入来自 Automation Technology、Azure Kinect、Benano、Heliotis、IDS Ensenso、Intel Realsense、Lucid Helios、LMI Gocator、Mech-Mind、Nerian Ruby、Photoneo PhoXi、 深圳SinceVision (SSZN)、Zivid等厂商的第三方3D传感器导入数据。该库能高效管理点云和ZMap数据,并支持进行3D处理与分析。
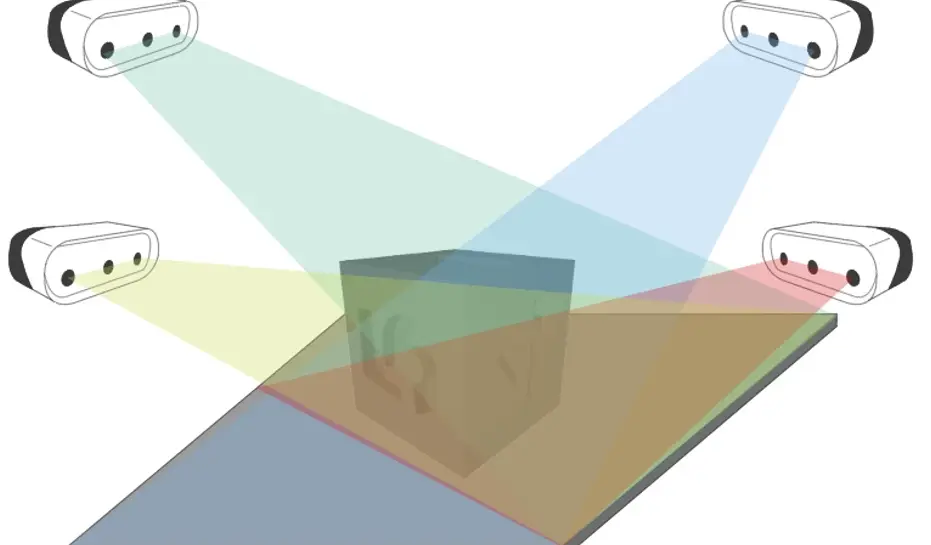
3D传感器融合
3D传感器融合是一项能够将同一物体不同侧面的点云进行合并的功能。您可以利用放置在多个位置的3D传感器,一次性获取物体的完整点云。 该过程分为校准阶段和合并阶段。因此,合并过程迅速,且校准过程与您希望采集的物体无关。最终,该流程将生成经过优化的点云,其中重复点已被移除,且合并后点云的所有属性(颜色、法线等)均得以保留。

3D 查看器
使用 Easy3D 的 3D Viewer 类来创建交互式 3D 显示。3D Viewer 可以显示点云和 3D 对象。它使用 OpenGL 接口,并需要兼容的显示设备。
其他福利
Neo 许可系统
Neo 是一款全新的授权系统。它可靠且技术先进,现已支持存储 eVision 和 eGrabber 授权。Neo 允许您选择在 Neo 加密狗还是 Neo 软件容器中激活授权。您先购买授权,稍后再决定。
Neo 加密狗采用坚固耐用的硬件设计,并支持在不同计算机之间灵活转移。Neo 软件容器则无需专用硬件,而是与激活它的计算机绑定。
Neo 随附专用的 Neo 许可证管理器,该管理器提供两种使用方式:直观易用的图形用户界面(GUI),以及可轻松实现 Neo 许可证流程自动化的命令行界面(CLI)。
适用于 Windows 和 Linux 的所有 eVision 库
- Microsoft Windows 11、10 适用于 x86-64(64 位)处理器架构
- Microsoft Windows 11、10 IoT Enterprise 适用于 x86_64 系统
- 适用于 x86-64(64 位)和 ARMv8-A(64 位)处理器架构的 Linux,需使用 glibc 2.18 及以上版本
eVision Studio
可以通过图形界面设计复杂的图像处理流程。这一系列工具体现了 eVision 库的多样性和强大功能。 与处理管道对应的 C++、Python 和 C# 源代码会自动生成,并为 eVision API 提供交互式文档。eVision Studio 可以处理实时图像源,例如千兆网相机、Coaxlink 图像采集卡或 eGrabber 记录仪序列。
该应用程序免费提供,可在 Windows 和 Linux 系统上运行,并兼容 Intel 和 ARM 64 位架构。
Software
- Host PC Operating System
-
eVision is a set of 64-bit libraries that require an Intel compatible processor with the SSE4 instruction set or an ARMv8-A compatible processor.
eVision can be used on the following operating systems:
Microsoft Windows 11, 10 for x86-64 (64-bit) processor architecture
Microsoft Windows 11, 10 IoT Enterprise for x86-64 systems
Linux for x86-64 (64-bit) and ARMv8-A (64-bit) processor architectures with a glibc version greater or equal to 2.18
Remote connections
Remote connections are allowed using remote desktop, TeamViewer or any other similar software.
Virtual machines
Virtual machines are supported. Microsoft Hyper-V, Oracle VirtualBox and libvirt hypervisors have been successfully tested.
Only the Neo Licensing System is compatible with virtualization.
Minimum requirements:
2 GB RAM to run an eVision application
8 GB RAM to compile an eVision application
Between 100 MB and 2 GB free hard disk space for libraries, depending on selected options.
- APIs
-
Supported programming languages :
The eVision libraries and tools support C++, Python and the programming languages compatible with the .NET (C#, VB.NET)
C++ requirements: A compiler compatible with the C++ 11 standard is required to use eVision
Python requirements: Python 3.11 or later is required to use the Python bindings for eVision
.NET requirements: .NET framework 4.8 (or later) or the .NET platform 6.0 (or later) are supported
Supported Integrated Development Environments:
Microsoft Visual Studio 2017 (C++, C#, VB .NET, C++/CLI)
Microsoft Visual Studio 2019 (C++, C#, VB .NET, C++/CLI)
Microsoft Visual Studio 2022 (C++, C#, VB .NET, C++/CLI)
QtCreator 4.15 with Qt 5.12
Ordering Information
- Product status
-
Released
- Product code - Description
-
PC4184 Open Easy3DMatch for USB dongle
PC4334 Open eVision Easy3DMatch
- Included libraries
-
Easy3D
Easy3DMatch
- Related products
-
PC6512 eVision/Open eVision USB Dongle (empty)
PC6514 Neo USB Dongle (empty)

